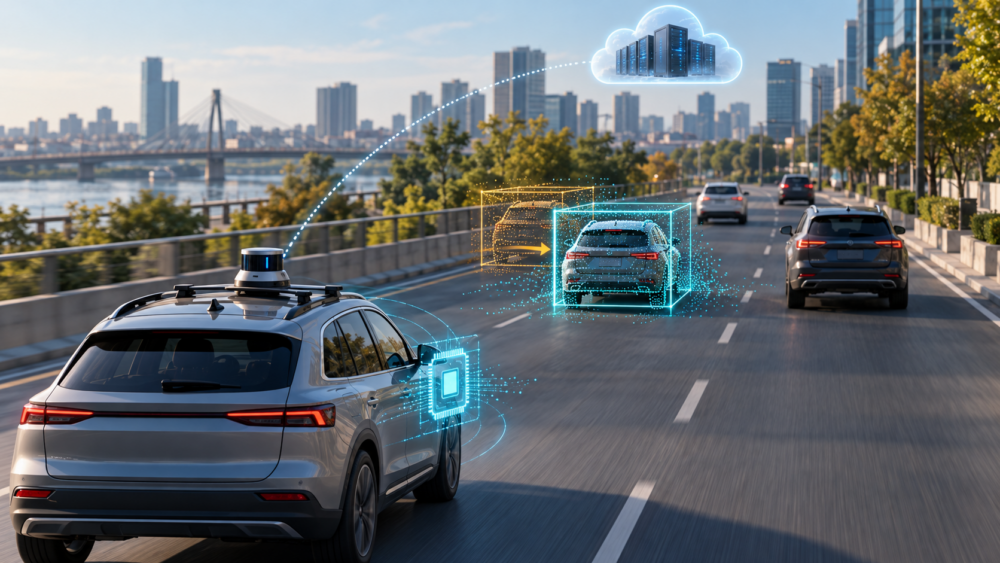
Can connected vehicles update their understanding of surrounding traffic without sending every LiDAR frame to the cloud? Our team at FIIT STU investigates this question in a paper published in the proceedings of the 2026 IEEE Vehicular Networking Conference (VNC). The proposed method uses previous object detections and current LiDAR measurements to refine vehicle positions and orientations locally, without running neural network inference at every timestep.
Addressing the Communication Cost of Offloaded Perception
LiDAR-based object detection requires substantial computing resources. Offloading this processing to cloud infrastructure can reduce onboard computational demands, but transmitting large point clouds from many vehicles can congest wireless networks, particularly in dense urban traffic.
Consecutive LiDAR frames often contain the same vehicles with only incremental changes in position and orientation. This temporal continuity creates an opportunity: reuse previous detections and update them locally between full detection cycles.
The study explores whether lightweight geometric refinement can provide sufficiently accurate localisation to support this approach.
What Is New?
The proposed method combines motion-based propagation with LiDAR-guided geometric refinement. It first estimates an object’s new position using its previous bounding box, velocity and orientation. It then selects nearby LiDAR points, filters ground reflections and refines the box centre and rotation.
The procedure updates the position and orientation of an existing object box without invoking a neural network. Its contribution lies in exploring this mechanism as a building block for hybrid perception offloading, where periodic remote detection could be complemented by intermediate local updates.
Improved Localisation on nuScenes
The team evaluated the method on the nuScenes dataset, using annotated frames separated by 500 milliseconds. The evaluation focused on moving vehicles within 50 metres of the sensor and with sufficient LiDAR visibility.
Localisation was assessed using bounding-box Intersection-over-Union (IoU) in bird’s-eye view. Mean IoU increased from 0.270 when previous boxes were reused unchanged, to 0.620 after motion propagation, and 0.665 after geometric refinement.
The strongest additional benefit of geometric refinement appeared at the stricter overlap threshold: the share of boxes reaching IoU ≥ 0.75 increased from 18.30% after motion propagation to 41.77% after refinement. Overall, 75.74% of refined boxes reached IoU ≥ 0.5.
A Python implementation ran on an Intel Core Ultra 7 255HX CPU without GPU acceleration, with an average processing time of 16 milliseconds per object and a median of 10 milliseconds. Because objects are processed independently, the procedure also offers opportunities for parallel execution.
Where Could Communication Savings Come From?
The study examined how frequently the set of observed vehicles remained unchanged. Across 33,299 compared frame pairs, 70.57% contained no newly appearing or disappearing vehicles under the evaluation constraints.
These observations identify potential opportunities for local updates between remote detections. They do not represent a measured bandwidth reduction: actual communication savings will depend on a future policy that decides when a frame requires full detection.
The experiments also used dataset annotations as a proxy for previous detector outputs, isolating the refinement mechanism from detector errors. Integrating a real detector, handling newly appearing objects and evaluating complete offloading policies are the next steps towards a practical system.
Publication at IEEE VNC 2026
The work appears in the proceedings of the IEEE Vehicular Networking Conference, a specialised international venue covering vehicular communications, V2X and connected and automated driving. The 2026 conference took place in Montréal, Canada, on 8–10 June 2026, as an IEEE Communications Society portfolio event.
Its value as a publication venue comes from its focused technical community, paper-review process and international programme committee spanning academia and industry. This makes VNC a relevant forum for research connecting vehicle perception with communication constraints.
The paper provides an initial experimental foundation for hybrid perception systems that combine remote detection with lightweight onboard refinement, working towards a better balance between localisation accuracy, computation and wireless bandwidth.
Authors: Branislav Fech, Nina Masarykova, Marek Galinski and Peter Truchly.
Read the paper: Towards Bandwidth-Efficient Perception Offloading in Vehicular Networks via Temporal LiDAR-Based Bounding Box Refinement